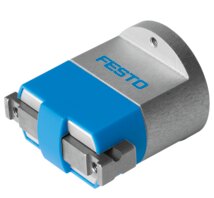
Genuine Festo product
Product family
HPPH
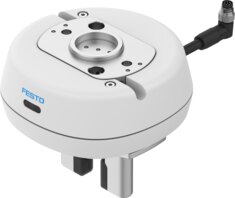
Parallel gripper
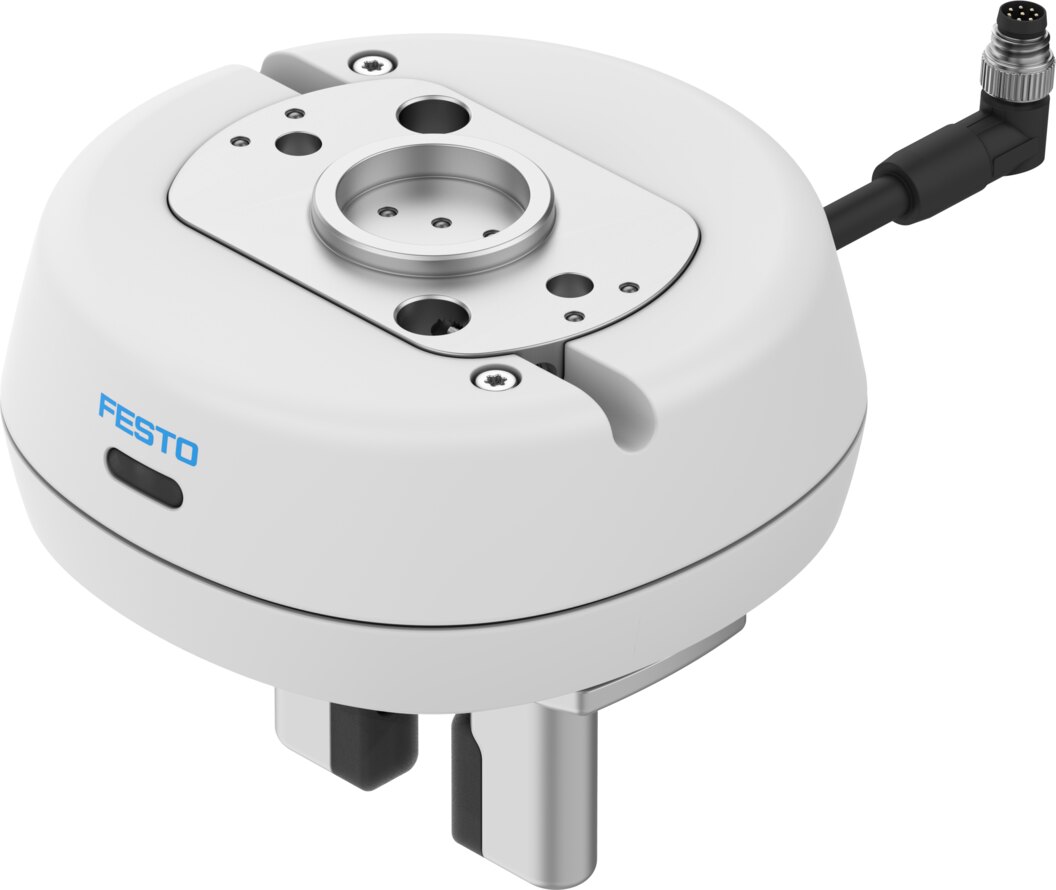
The parallel gripper/valve combination HPPH was specially developed for human-robot collaboration and can be combined with many cobots or robots thanks to its universal robot interface. The low overall height with a low mass moment of inertia ensures high dynamics.
Highlights
- For safe human-robot collaboration up to 0.5 MPa
- Gripper/valve combination with integrated sensors and low overall height
- Reduces cycle times and saves up to 75% on compressed air compared to using individual components
- TÜV certification for grippers with fingers to ISO 15066
- Can be used with many different cobots and robots thanks to the mechanical robot interface to ISO 9409-1-50-4-M6
- Gripping force backup for safe handling, even in emergency off mode
- Versatile control via digital I/O (PNP/NPN) or IO-Link®
- Sustainable in production thanks to reduced use of materials
- Sustainable operation thanks to integrated control
Price and delivery are confirmed with the quote. Requests received during business hours are answered the same day.
Products in this product family
4 variants| Product | Part no. | Design | Stroke per gripper jaws | Position detection | Pneumatic connection | ||
|---|---|---|---|---|---|---|---|
| HPPH-16-16-NC-P-R12 Parallel gripper | 8171874 | Flat mounting method for gripper fingers, Guidance, Rack and pinion, With gripper finger, Pneumatic gripper, Force pilot operated motion sequence | 8 mm | Via integrated displacement encoder | For push-in connector O.D. 4 mm | ||
| HPPH-16-16-NC-N-R12 Parallel gripper | 8171873 | Flat mounting method for gripper fingers, Guidance, Rack and pinion, With gripper finger, Pneumatic gripper, Force pilot operated motion sequence | 8 mm | Via integrated displacement encoder | For push-in connector O.D. 4 mm | ||
| HPPH-16-16-NC-P-SR12 Parallel gripper | 8205393 | Flat mounting method for gripper fingers, Guidance, Rack and pinion, With gripper finger, Pneumatic gripper, Force pilot operated motion sequence | 8 mm | Via integrated displacement encoder | For push-in connector O.D. 4 mm | ||
| HPPH-16-16-NC-N-SR12 Parallel gripper | 8205392 | Flat mounting method for gripper fingers, Guidance, Rack and pinion, With gripper finger, Pneumatic gripper, Force pilot operated motion sequence | 8 mm | Via integrated displacement encoder | For push-in connector O.D. 4 mm |
Diagrams
Diagrams open in Festo's interactive diagram tool in a new tab.